|
Nikita Sarawgi I am a robotics and AI engineer at GrayMatter Robotics, working on decision-making for robots in semi-structured environments for high-mix manufacturing. I completed my M.S. in Computer Science at USC in December 2025, advised by Satyandra K. Gupta and Daniel Seita, and worked closely with Omey M. Manyar. I want to build robots that are robust and reliable enough to be deployed in production and to work alongside people. I believe this requires structured, compositional systems built on learned abstractions, so that a robot’s decisions are interpretable and its components can be reused across tasks and environments. My interests center on four connected questions: what state and action abstractions a robot should learn, how skills and behaviors should be bounded and composed for long-horizon tasks, how a robot can continually detect and acquire knowledge it is missing, and how that knowledge can be integrated into its existing abstractions for later reuse. I am currently applying for PhD positions for Fall 2027. |
|
Updates |
| November 2026 | I'll be at CoRL 2026 in Austin for our work at the Do Robots Need World Models? workshop. Please reach out if you are around and would like to connect! |
| September 2026 | Wrote a blog post with GrayMatter Robotics on scene understanding in manufacturing environments. |
| August 2026 | Wrote a blog post with GrayMatter Robotics on what it takes to autonomously commission robotic cells. |
| May 2026 | I'll be attending ICRA 2026 in Vienna this June. Please reach out if you are around and would like to connect! |
| February 2026 | I joined GrayMatter Robotics full-time as a robotics and AI engineer. |
| January 2026 | Our paper, STEP, was accepted to ICRA 2026. Hope to see you in Vienna! |
| December 2025 | I completed my M.S. in Computer Science from USC Viterbi. |
| October 2025 | I joined GrayMatter Robotics as a robotics intern, working on translating learning-based manipulation research into deployable perception and control systems for high-mix manufacturing. |
Publications |
|
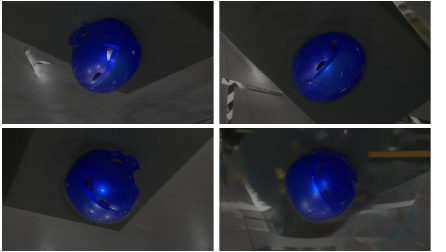
Incorporating World Models in Decision Making for Next Best View Selection in Active Sensing
Nikita Sarawgi, Omey M. Manyar, Satyandra K. Gupta CoRL Workshop: Do Robots Need World Models?, 2026 arXiv |
|
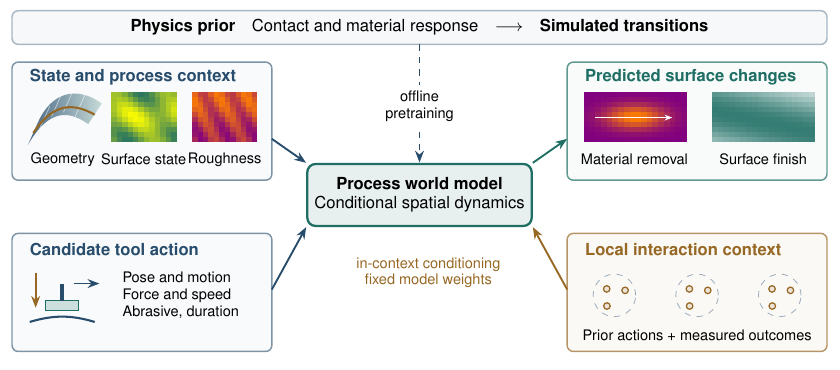
Industrial Autonomy Requires World Models within an Execution Harness
Omey M. Manyar, Sagar Jatin Joshi, Samrudh Moode, Nikita Sarawgi, Hantao Ye, Satyandra K. Gupta CoRL Workshop: Do Robots Need World Models?, 2026 |
|
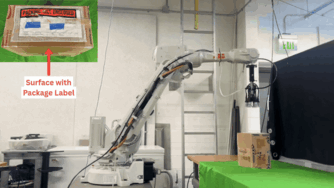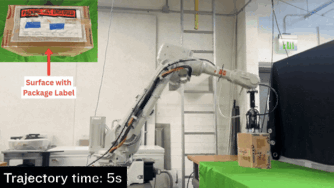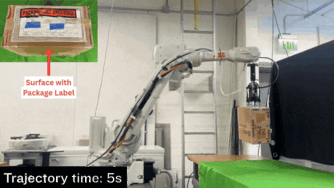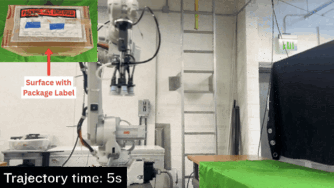
Preference-Conditioned Reinforcement Learning for Space-Time Efficient Online 3D Bin Packing
Nikita Sarawgi, Omey M. Manyar, Fan Wang, Thinh H. Nguyen, Daniel Seita, Satyandra K. Gupta ICRA, 2026 project page / arXiv / code An RL policy for online 3D bin packing that chooses both the next item to pack and the face to grasp it on. A preference parameter set at inference time trades off packing density against operation time without retraining. |
|
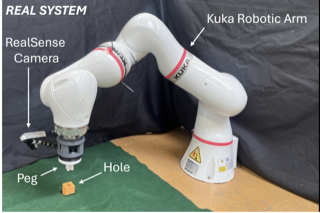
Autonomous Execution of Insertion Operations in Space Assembly Tasks
Abhay Negi, Nikita Sarawgi, Dhanush Penmetsa, Hantao Ye, Omey M. Manyar, Ashtin Cheng, Satyandra K. Gupta AIAA SciTech Forum (ISAM IV), 2025 paper An autonomous insertion system for in-space assembly. The robot first estimates a coarse pose to position a wrist-mounted camera near the target, then uses a learned model to estimate fine misalignment, and executes the insertion under impedance control. |
Academic Service |
|
|
Website adapted from Jon Barron's website. |